Decide
Operator base station & onboard processing
+THE ROVER / DESIGN IN DEVELOPMENT
A six-wheel platform, a robotic arm and onboard computing. Explore how the planned subsystems connect, then try the steering concept for yourself.
+EXPLORE THE SYSTEMS
The features below describe the design under development. Performance and readiness will be established through testing.
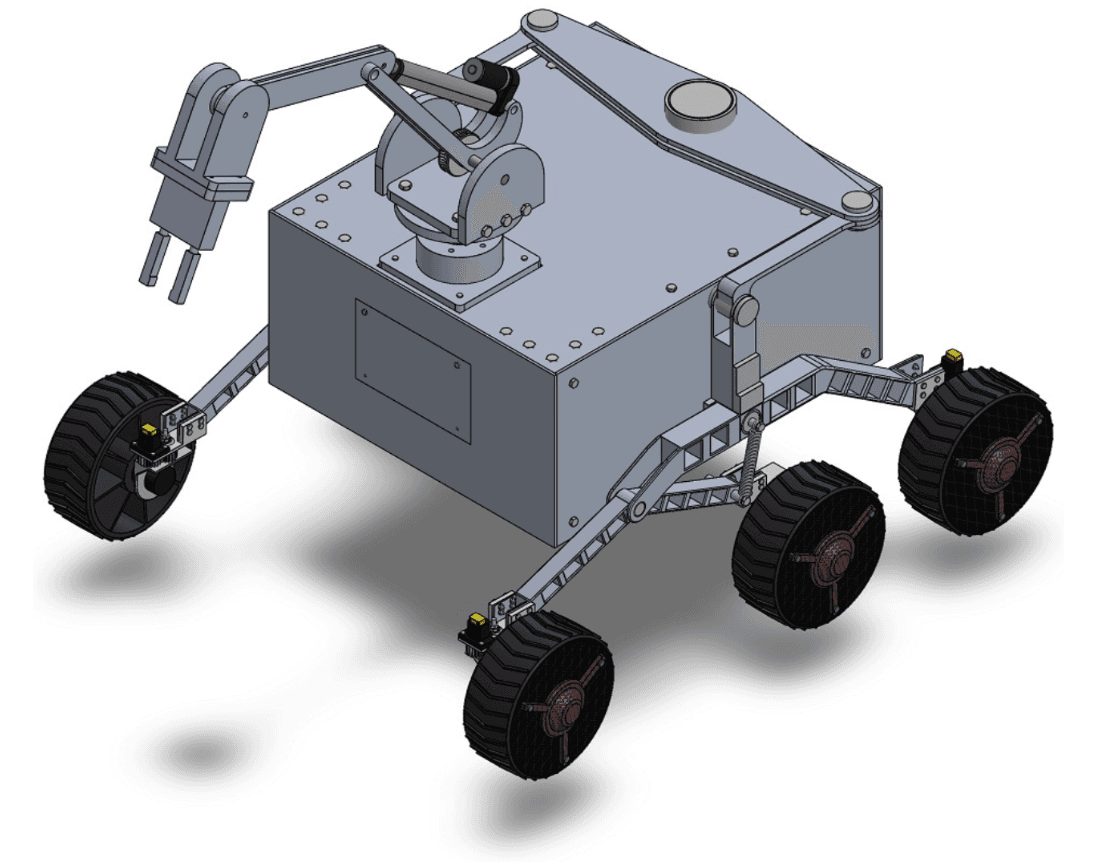
Six driven wheels and four independently steered corner wheels are planned around a rocker-bogie suspension for uneven terrain.
06 WHEELS / 04 STEERING CORNERS
The concept uses six driven wheels, with independent steering at the four corners. This simplified model shows how the front and rear pairs can turn in opposite directions while the centre pair stays aligned.
An illustrative steering study, not a performance simulation. Control angles and drawing proportions are not vehicle specifications.
+02 / FROM COMMAND TO ACTION
The planned architecture connects operator input and onboard decisions to local controllers, actuators and sensor feedback.
Operator base station & onboard processing
CAN communication & STM32 interfaces
Drive, steering & arm mechanisms
Camera, depth, LiDAR & inertial feedback
Power protection and hardware emergency isolation sit alongside this control concept. Component selection, interfaces and performance remain subject to integration and testing.
+03 / THE TASKS AHEAD
These intended task areas guide development, subject to team readiness and competition review.
Prepare the rover for operation and work through initial mission procedures.
Develop the mobility and manipulation needed to interact with a simulated exploration site.
Work toward selected mission tools and autonomous behaviours, with evidence built through testing.