01 / MOBILITY
Traverse.
A six-wheel platform designed around terrain, traction and control.
+KFUPM ROVER TEAM · SAUDI ARABIA
A student team. A six-wheel rover. A shared drive to explore what comes next.
We are Banu Mousa, developing a rover at KFUPM in preparation for the Australian Rover Challenge 2027.
+01 / THE MISSION
Mechanical engineering, electronics and software are only the beginning. The real challenge is making them work together.
Meet Banu MousaA six-wheel platform designed around terrain, traction and control.
An arm and mission tools that connect the rover to the world around it.
Sensors, onboard computing and operator tools working toward informed decisions.
+02 / EXPLORE THE ENGINEERING
Select a system to understand its role in the design. Each part contributes to the same mission.
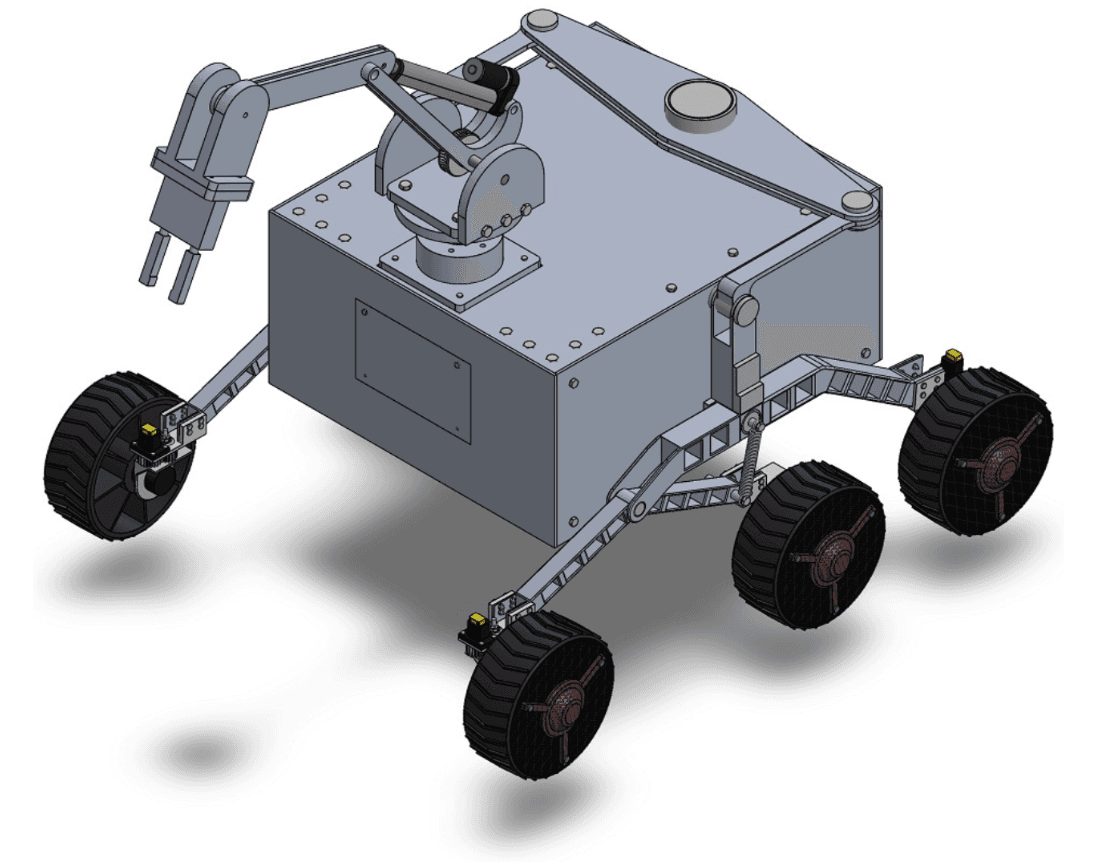
Six driven wheels and four independently steered corner wheels are planned around a rocker-bogie suspension for uneven terrain.
06 WHEELS / 04 STEERING CORNERS
+03 / THE PEOPLE BEHIND THE PROJECT
Four committees. Shared interfaces. One engineering team.
How the team works+04 / FROM IDEA TO EVIDENCE
Our current work focuses on design review, component selection and integration planning. Fabrication, subsystem testing and full-rover validation are the next stages.
Translate mission needs and competition rules into engineering requirements.
Develop and review the mechanical, electrical and software architecture together.
Plan fabrication and connect subsystems through staged checks.
Test requirements and document evidence before mission trials.
+THE NEXT HORIZON
The Australian Rover Challenge brings student teams together to develop rovers for simulated exploration tasks. We are preparing around Post-Landing, Site Preparation, and Excavation & Autonomy. These are intended task areas, subject to team readiness and competition review.
About the competitionRoseworthy Campus
South Australia